When plugging in your fc to bf, make sure your fc is still. Then if its still all over the place, reduce the gyro frequency. To hard filter the noise. If its still all over the place then that’s life 
Here’s another nice graph
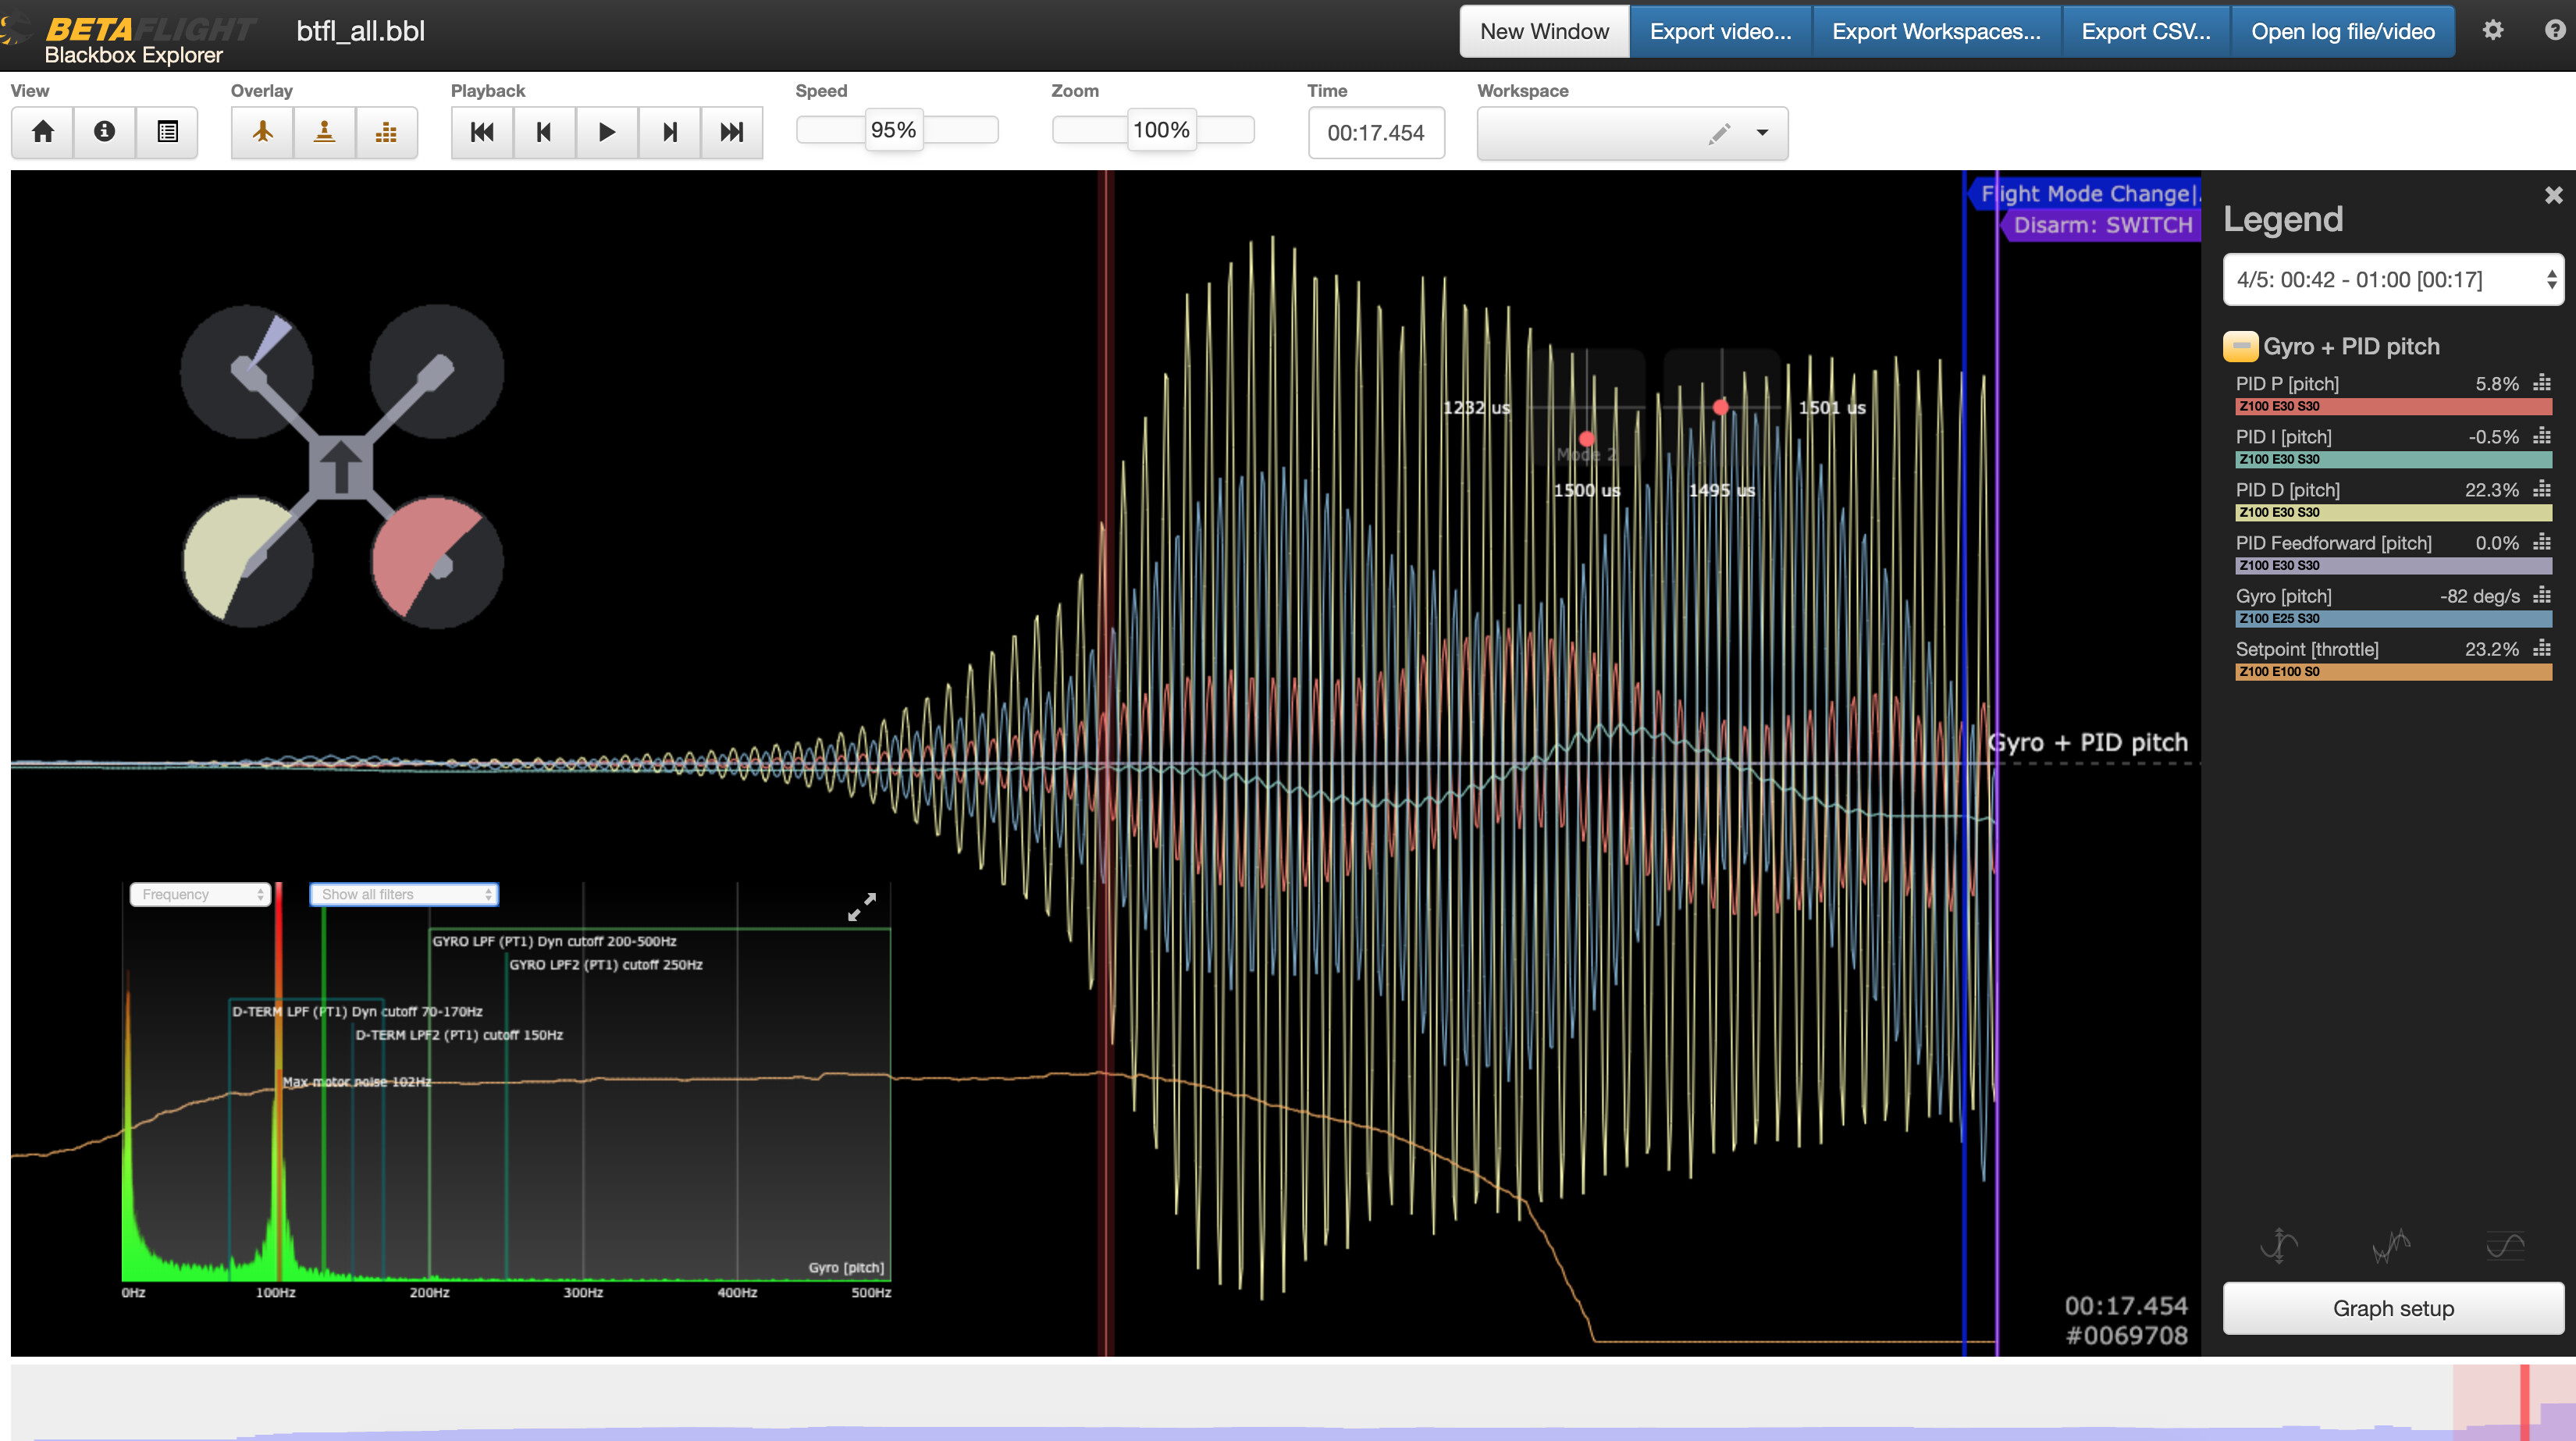
The usual out of control PIDS, but this one nicely shows the 100hz peak in the frequency graph.
Hmmm… What frequency is the packet rate in your control link? Is it also 100Hz?
There was something in the BF 4.3 Presets about setting RPM filtering to match it.
I reckon you could calculate what speed to spin the props at in bf to recreate this resonance
About 18-20% throttle, so would be easy to replicate by dragging the little slider up to about 1200, yes. Not a chance I’m doing that in my dining room with the props on though! 

Hmmm, wonder if one of the motors is bent or unbalanced…
1 Like
I’ll check. Should be the same as all my other quads as I just duplicated the model settings from my 5" Nazgul. Actually it’s Tracer, so it’s fixed at 250Hz (until they release their LoRa update).
OK - Haven’t posted anything here for a week or so because I’ve been diving pretty deep into this stuff on Discord on the FPVKnowItAll server (Josh Bardwell), the Chris Rosser server (expert on frame resonance and filtering etc) and also the TBS Source One server.
It would take pages and pages to describe all the troubleshooting I did - but in summary, there was too much filtering on a standard Betaflight setup for this particular quad. Excessive gyro filters lead to PID latency that was sending it into a positive feedback loop, constantly playing catchup and gradually amplifying itself. I got rid of the two default gyro lowpass filters and things immediately got better. I still have some tweaking to do on some of the other filters as I still have some D-Term oscillation at around 100hz which I don’t like at all, but fortunately this isn’t making its way into the motors - there are some wobbles in flight which I need to smooth out, but most of the time the motors are running smooth and they always come down cool now.
The PIDs need to be sharpened up a little, but stick repsonse and general handling feels ok. I’ve just been out and flown my first proper FPV flight and recorded some logs, so I’ll take a look at those this evening.
I did a quick flight on Saturday, but the vtx signal was almost unflyable, once the motors started spinning. I moved the camera on the same 5V and GND pads as the VTX and the nasty banding has gone now. Still some slightl electrical noise but perfectly flyable. I need to replace the 470uf capacitor with a 50v 1000uf one, but nowhere has them in stock at the moment.
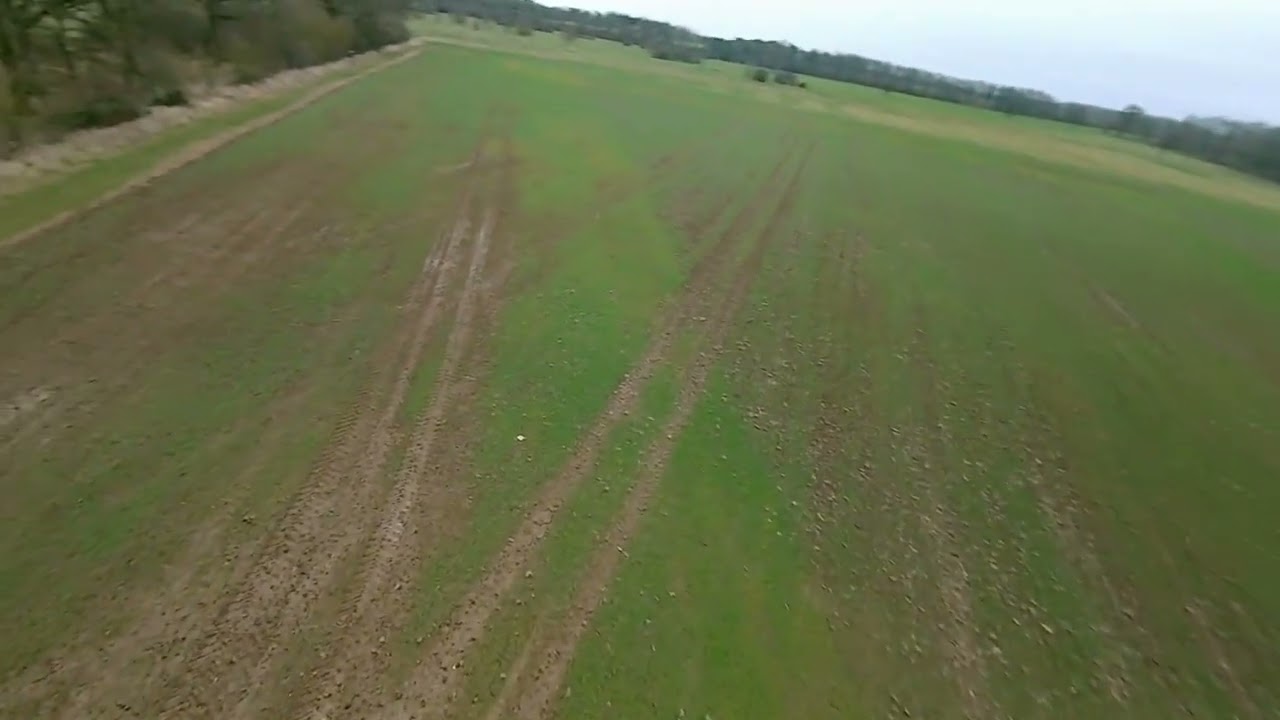
Little bit of crappy video from lunchtime today. Flies ok, just quite wobbly when in a hover state which I need to look at.
5 Likes
Looks like it could get up to some pace that!
Yeah, it hovers at about 15-20% throttle and I don’t think I went above 40% today. I’ve got a very shallow camera angle at the moment so, yeah, I’d imagine it’d shift if you gave it some beans!
Nice big fields
Who owns them?
Possible ‘Big Meet’ site 
Dunno, some farmer. Not ideal as a big meet site though - there’s a high-security prison not far away. Depending on which bit of the field you’re in, you can be in the NFZ for it. I tend to stay down the other end and keep nice and low.
You can hear that the motors sound like they will have some punch. Think I’d be tempted to open it up
 I will. It was the first proper flight though, so just making sure things aren’t overheating and vtx is working as it should. My step response graph in PIDToolbox looks pretty shit, so I need to work on that a bit. This weather is frustrating, if it was sunny and calm now I’d be out a couple of times a day and would have 10 flights in in no time. I’m managing more like one a week at the moment though

Totally understand. I’m still waiting to get my Nazgûl up in the air after going hd two weeks ago.
A combination of weather and work have meant zero flight time  .
Sounds very technical with the rates.
Not something I’ve played around with as yet
Decided to go out and fly another pack at lunchtime despite it blowing about 20mph at the moment. 4 short flights, gradually increasing the P/I gain each time
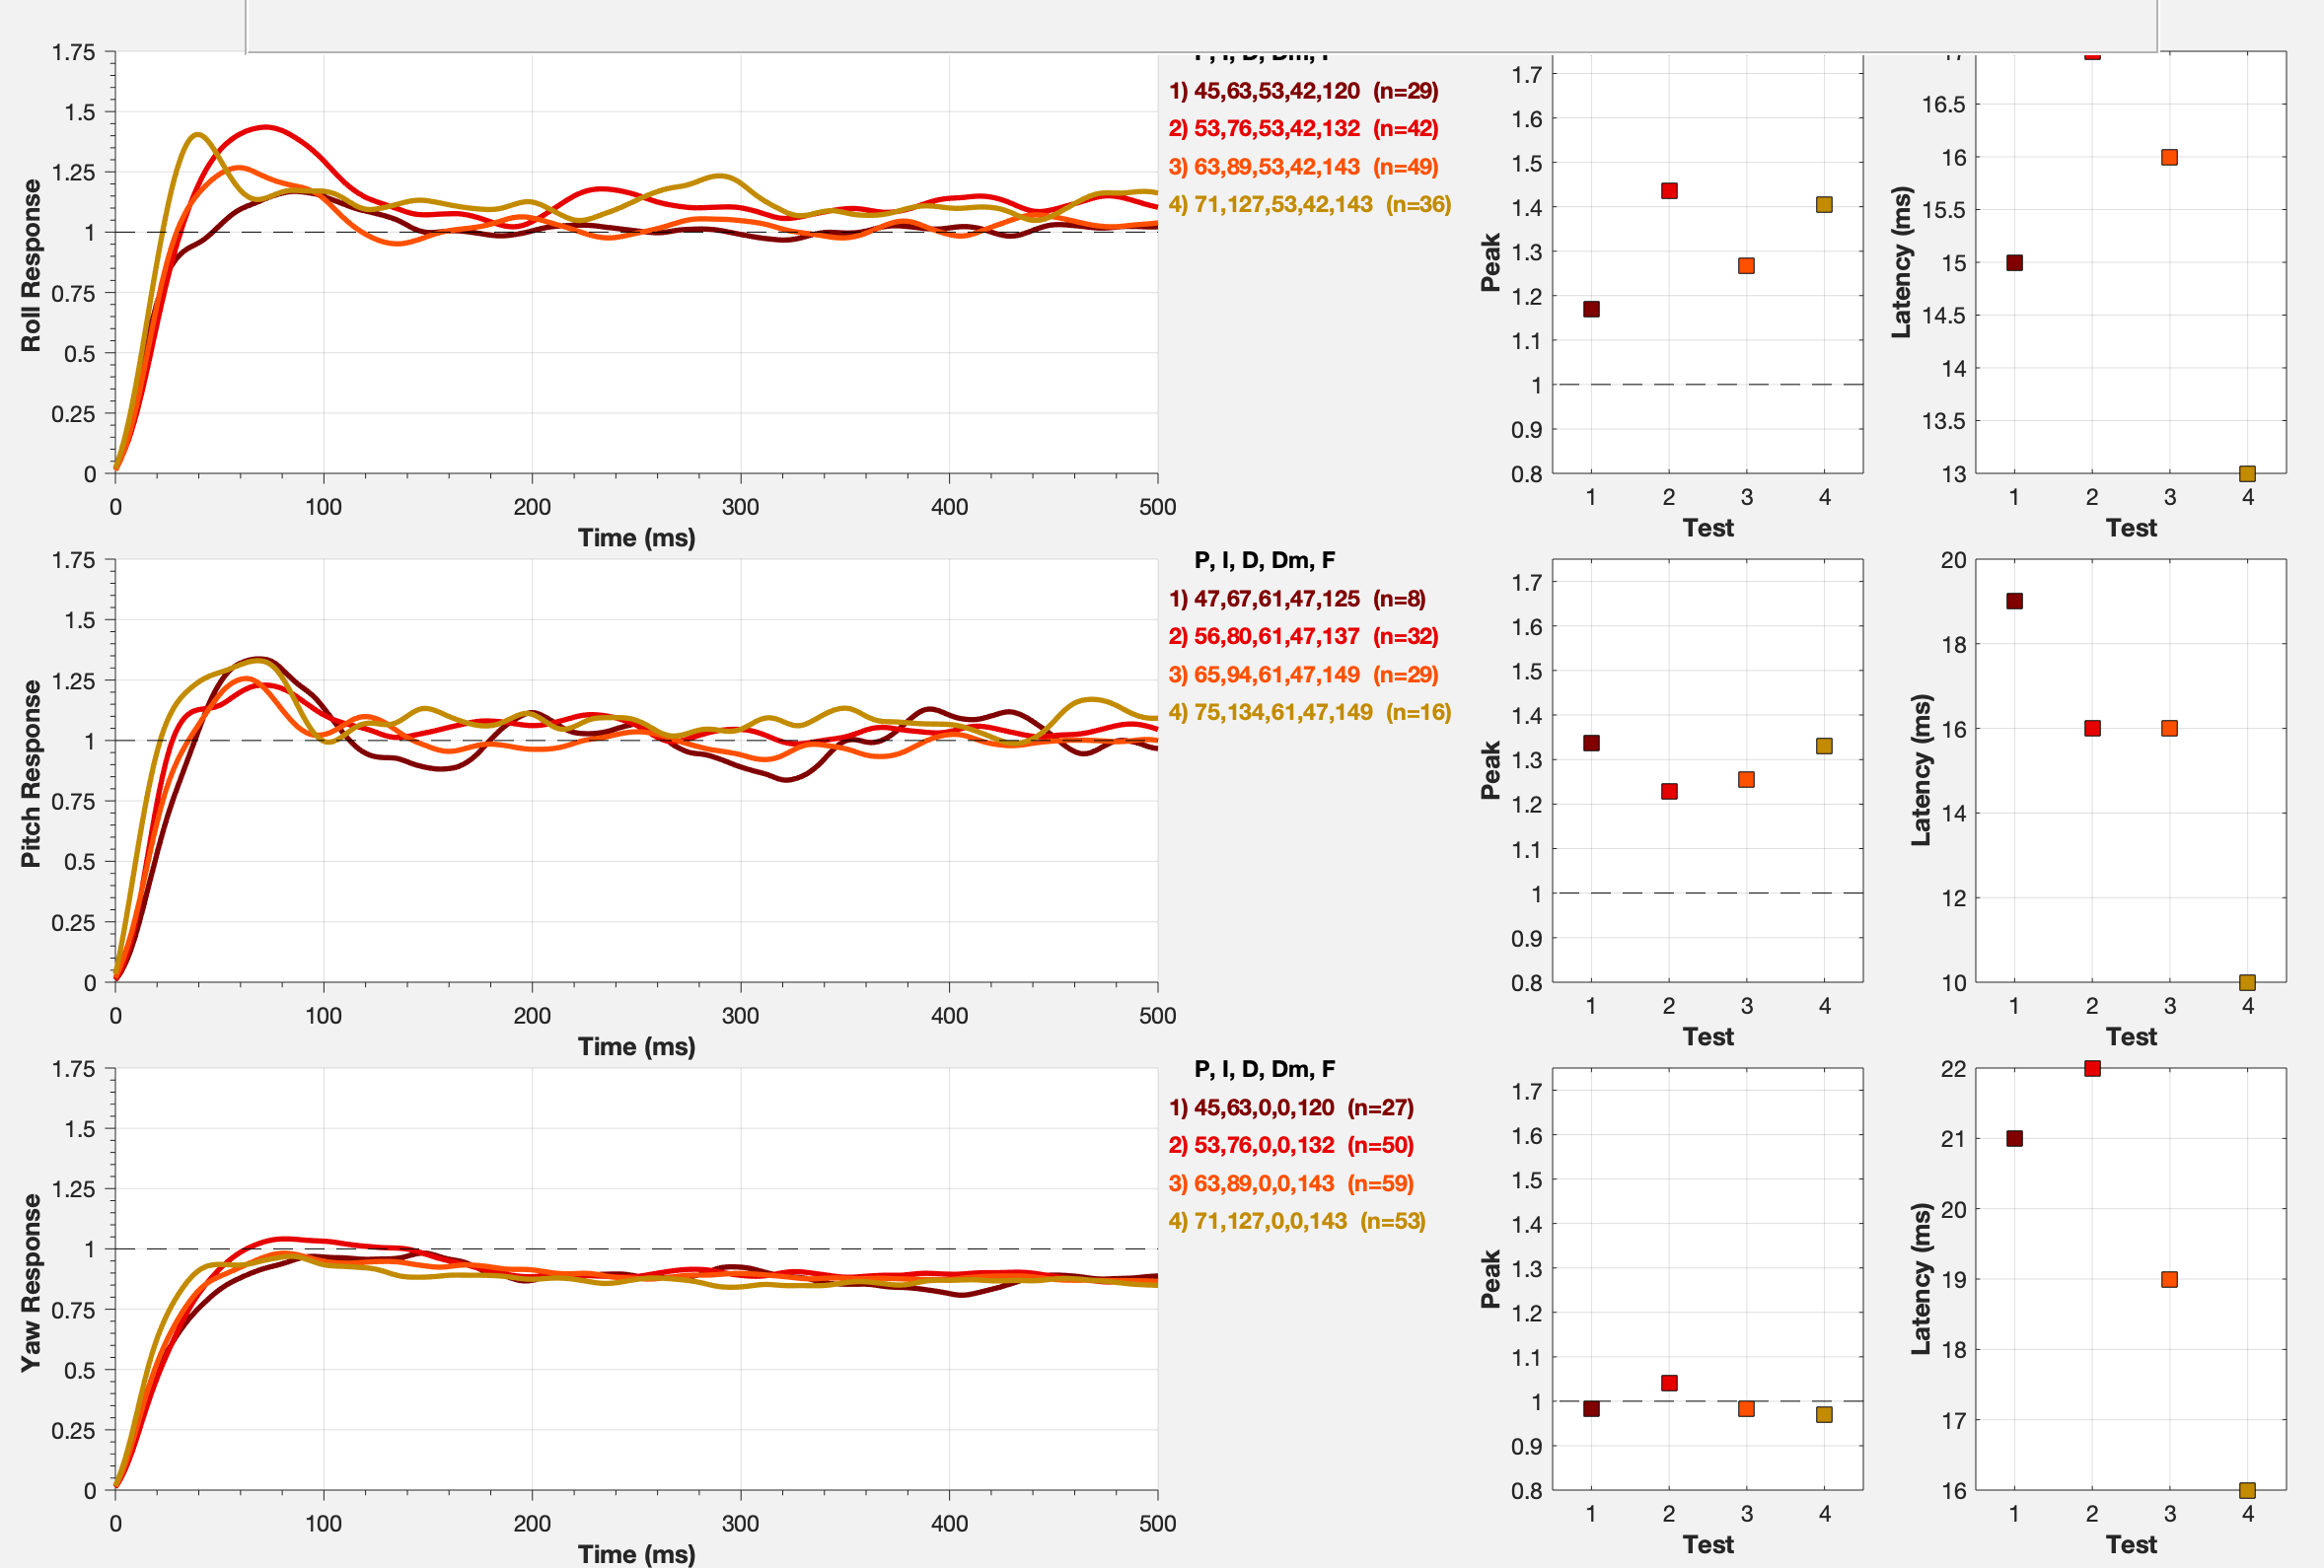
Managed to cut the latency almost in half, which is good. It actually feels pretty decent in the air. Some slight overshoot on the graph to look at now, perhaps a little more d-term required. Also still some oscillations here and there which will be a filtering thing I guess. I feel like I could go out and enjoy a flight on this now though, which is great.
Flight time seems decent on a 1500mah battery. Not sure exactly what it’ll do because I keep unplugging/disarming etc to change things. I reckon 8-10 minutes should be fine though. And I’d quite happily stick a 2200 on there which would give 14-15 minutes.
2 Likes
The wind dropped yesterday so went for another fly about.
Ropey quality video (forgot to change it from a high ISO setting), but good enough that you can see it’s pretty smooth now. It’s got a lovely swoopy feel about it, makes you just want to do big cinematic carving turns over huge landscapes.
Not the best plane following ever, but I found it much easier than in the 5" with its twitchy throttle and lightning response

It’s been a tough build, but I’m really happy with this.
3 Likes
Looks great… nice and smooth…
Some thoughts, while I’m sat here working and my quad is on my desk with the top plate off waiting to have a new cap fitted…
The deadcat layout on this puts the rear motors closer together than the front motors. The fronts sit about 2/3cm further out than the rears.
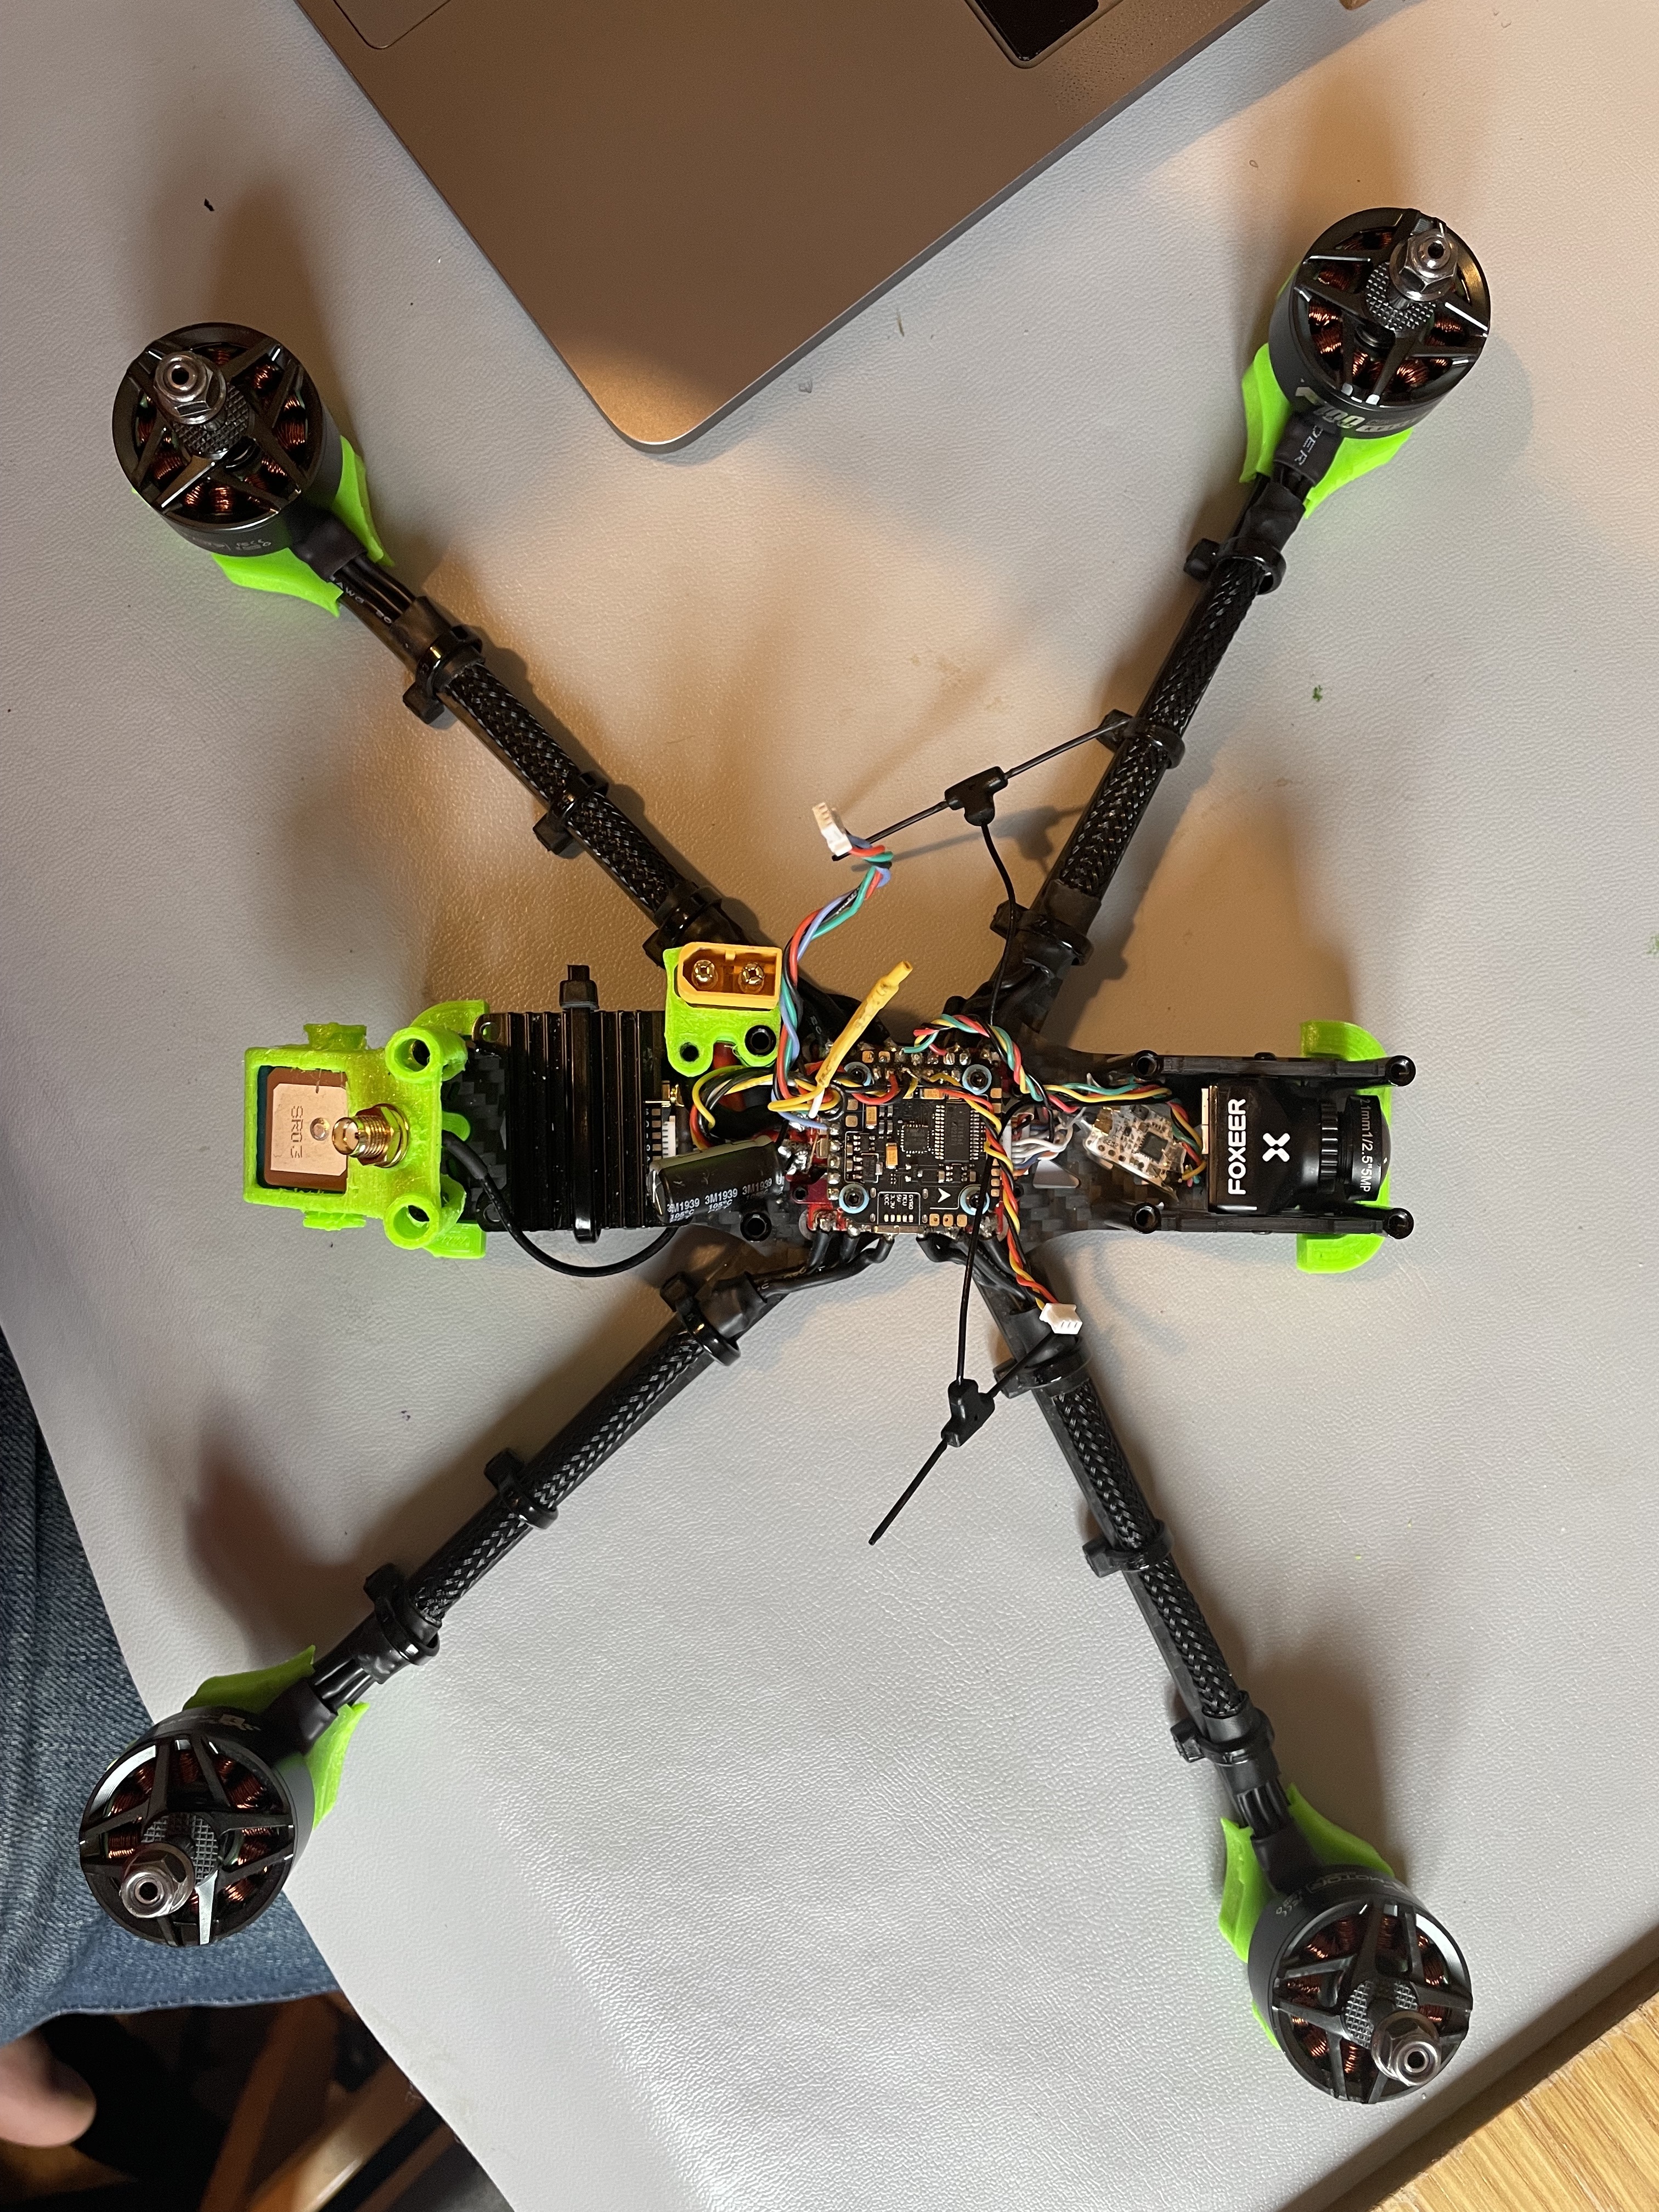
Those front motors have extra roll leverage and so, in a roll maneuver where the FC will theoretically apply an equal amount of extra power to the front and rear motors on one side of the quad, the front motor will have more authority. This will presumably cause some slight pitch back effect that the PID controller will then have to counteract by increasing the power to the rear motor to compensate. Which doesn’t seem ideal.
All the oscillation problems I’ve had on this quad have mostly been on the pitch axis, which would be consistent with this observation.
Mostly I have things tuned so that I can cruise around smoothly now, although if I really ramp it up to full thorttle I still get some pretty bad vibrations.
Are there any/many other quads that have unevenly spaced front/rear motors? Have I mounted the arms wrong? Should I try another frame? Does my theory on uneven leverage even make sense?
The TBS Discovery frame, which has been out for years, is very much this configuration,
It’s primarily a freestyle/cine frame not a racer. I’m not aware of any problems with it, the controller just handles it 
1 Like
There is mmix cli commands to program the motor spacings in inav. Not sure if it will help though.
1 Like